
Built for Developers
Real Code, Real Robot
Every course ships sample code that runs on the Unitree G1, not a toy simulator.
Current Stacks
ROS 2, MuJoCo, Isaac Sim, GR00T, UniFoLM and DimOS, taught by practitioners.
Go at Your Pace
Short, focused lessons you can work through between builds.
Developer courses
Pick Up Where Your Stack Is
From the Unitree SDK and ROS 2 to simulation, Sim2Real and VLA. Buy one course or get them all.
 Free preview
Power on, connect, update and safely operate the Unitree G1 humanoid. A quick-start course with 6 short video lessons, from first setup to safe packing.
 Beginner
 6 lessons
 ~7 min
 Beginner
 6 lessons
 ~7 min

Generate, guide and export Unitree G1 humanoid motion data with Kimodo: text-prompted motion, keyframes, constraints and CSV export. Beginner friendly.
- Beginner
- 12 lessons
- 12+ hours
 Free preview
Install ROS 2, build Python and C++ packages, integrate the Unitree G1 SDK with a ROS-to-SDK bridge, then run the same control workflow safely in MuJoCo.
 Intermediate
- 21 lessons
- ~2–4 hours
 Intermediate
 Free preview
Simulate, tune and visualize Unitree G1 humanoid motion in MuJoCo: setup, physics control, motion replay and 3D dataset visualization with Rerun.
- Intermediate
- 10 lessons
- 20 hours

Build a real-time WebRTC command pipeline for Unitree Go2 and G1 with z4rtc: LAN connection, locomotion and gestures, video and audio streaming, LiDAR.
- Intermediate
- 12 lessons
- 18 min of video
 Free preview
Install DimOS on the Unitree G1 and build autonomy: navigation engine, perception, AI agents, mapping, autonomous navigation and custom agent skills.
- Intermediate
- 15 lessons
- 12+ hours
 Free preview
Build and deploy Vision-Language-Action systems on the Unitree G1: visual navigation, dexterous manipulation and world modeling with UniFoLM and GR00T.
 Advanced
- 9 lessons
- ~3–6 hours
 Advanced

Take the Unitree G1 from keyboard locomotion to autonomous manipulation with NVIDIA GEAR-SONIC and GR00T N1.6: teleop, data, fine-tuning and deployment.
- Advanced
- 8 lessons
- ~8–12 hours
 Free preview
Build, train and deploy locomotion policies with NVIDIA Isaac Sim, Isaac Lab and RSL-RL, then transfer them to a real robot. An end-to-end Sim2Real course.
- Advanced
- 7 lessons
- ~3 hours
 Free preview
Teach the Unitree G1 humanoid to move from human video: build motion datasets, train control policies and deploy them on a real G1 with HDMI.
- Advanced
- 6 lessons
- ~4–5 hours
 Free preview
Go from a fresh RoboJuDo install to real-hardware deployment on the Unitree G1 (29-DOF): architecture, policies, pipelines and safe simulation practice.
- Advanced
- 10 lessons
- 8–10 hours

Collect demonstrations, clean LeRobot datasets, fine-tune an Isaac-GR00T N1.7 VLA policy and deploy it on the Unitree G1 with PolicyServer.
- Advanced
- 8 lessons
- 5–8 days
For developers
What You’ll Actually Work with
The real tools, frameworks and workflows inside the courses, grouped by stack. Every line comes straight from a course syllabus.
ROS 2 & the Unitree SDK
- Create ROS 2 workspaces and build Python/C++ packages with colcon
- Understand nodes, topics, message types, and implement publisher/subscriber patterns
- Read joint states, send position commands, and apply safety limits via SDK control
Simulation
- Solver tuning for stable humanoid motion
- Environmental & contact physics configuration
- Working with USD, PhysX, and scene composition
In: MuJoCo Simulation for the G1, Sim2Real Reinforcement Learning, RoboJuDo Control Policies
Reinforcement Learning & Sim2Real
- Designing rewards, terminations, and randomizations
- Generating terrains and difficulty curricula
- Training PPO locomotion agents with RSL-RL
In: Sim2Real Reinforcement Learning, RoboJuDo Control Policies
VLA & Robot Foundation Models
- Use UniFoLM-VLA for dexterous manipulation tasks (pick, place, sequence)
- Deploy end-to-end Vision-Language-Action pipelines on a humanoid robot
- GR00T N1.6 Training & Evaluation Basics
In: Vision-Language-Action on the G1, GR00T Whole-Body Control, Teaching the G1 New Skills
Motion Data & Retargeting
- Extracting human motion from monocular video
- Mapping human kinematics to the Unitree G1 joint structure
- Human motion transfer concepts (LAFAN1)
In: HDMI: Human-to-Motion, Kimodo Motion Generation, MuJoCo Simulation for the G1, RoboJuDo Control Policies
AI Agents, Navigation & Real-Time Control
- Environment Mapping & Autonomous Navigation
- Browser-Based Control with z4web
- AI Agent Commands, Detection & Tracking
The complete bundle
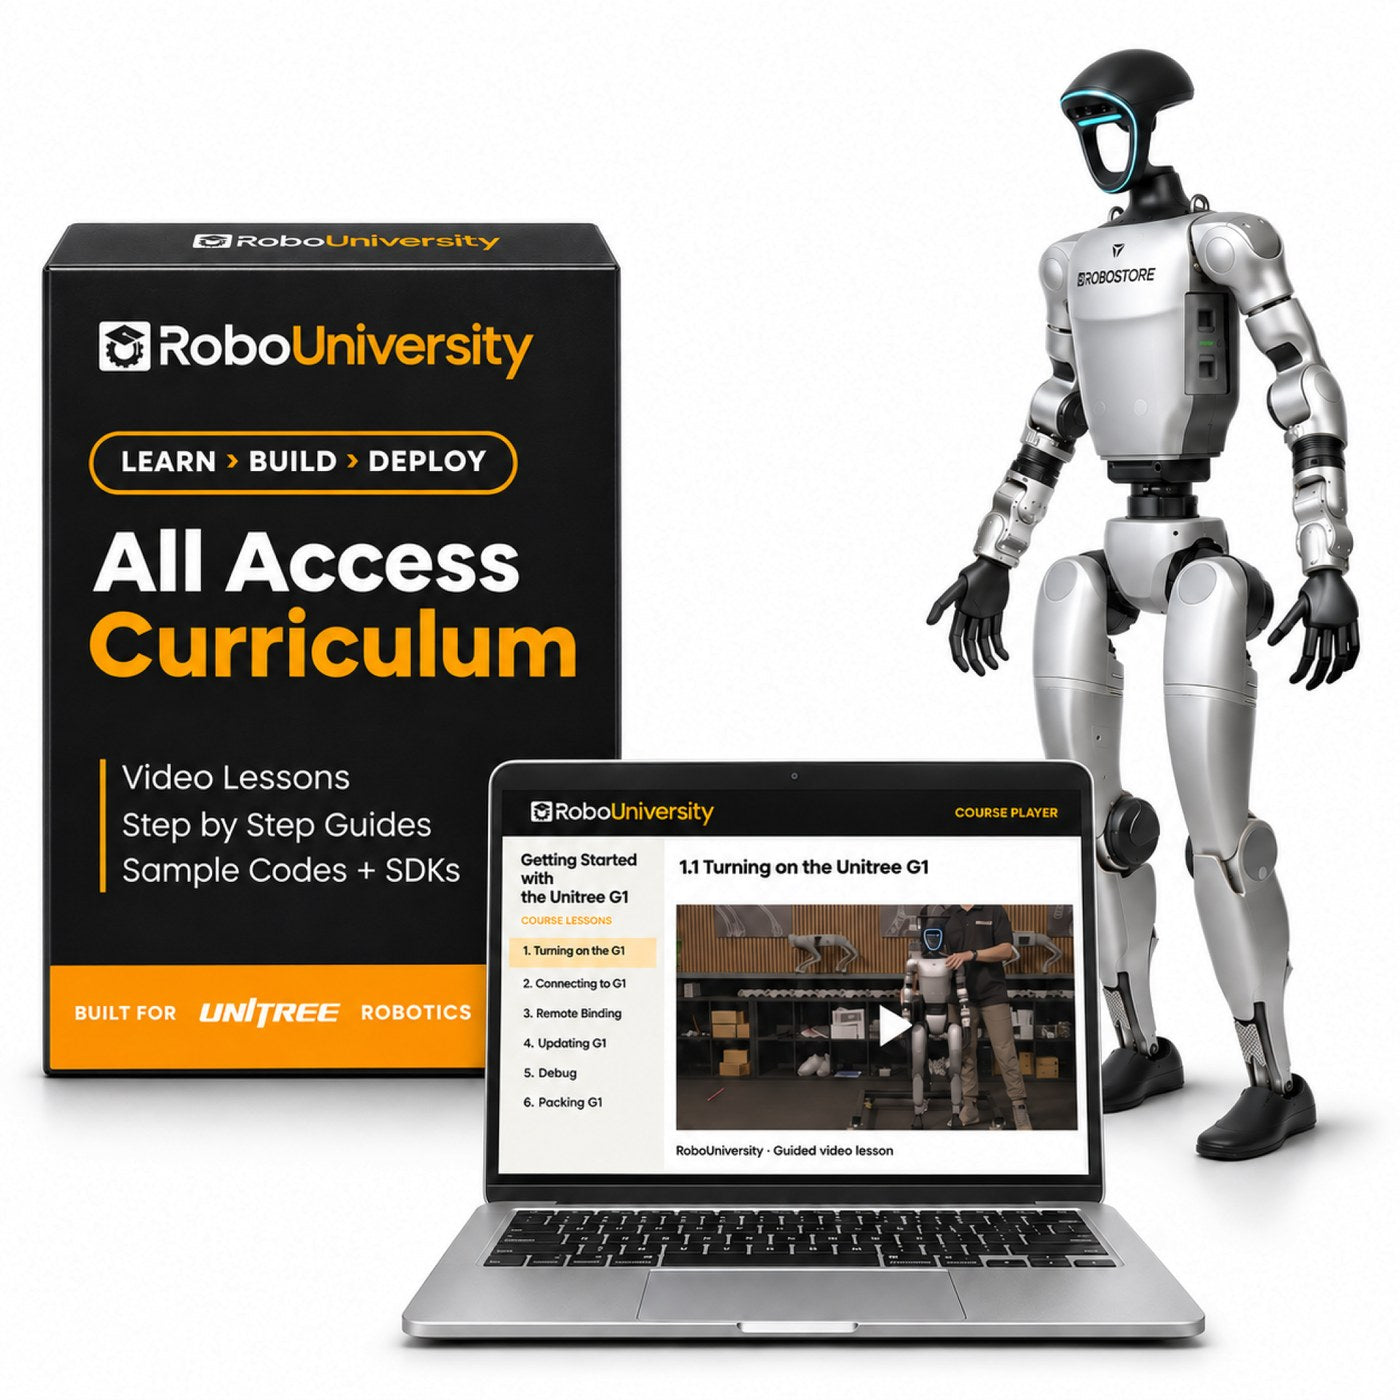
G1 EDU + Curriculum Bundle
From $47,700robot + All-Access
- Unitree G1 EDU humanoid, your choice of model
- Every current course, plus future releases for 1 year at no extra cost
- Enterprise-wide license, all seats included
Educator FAQ
Does All-Access Cover a Whole Class or Team?
Yes. All-Access is an enterprise-wide license, so it covers every seat in your organization. Speak to an expert and we’ll set it up.
How Does Access Work After I Buy?
Courses are delivered through RoboUniversity’s online classroom. After checkout we email your login, and you can return any time from Class Login.
What Hardware and Software Do I Need?
You would typically need a Unitree G1 and a computer. Some courses specifically require a Linux operating system, Python, and potentially software like Isaac Sim or the Unitree Explore app.
Get in touch
Prefer to talk?
Book a Discovery Call
Tell us about your team and robots, and we’ll put the robot and the curriculum on one quote.