Course at a Glance

Robot

Video lessons

Time to complete

Level

Prerequisites

Of completion
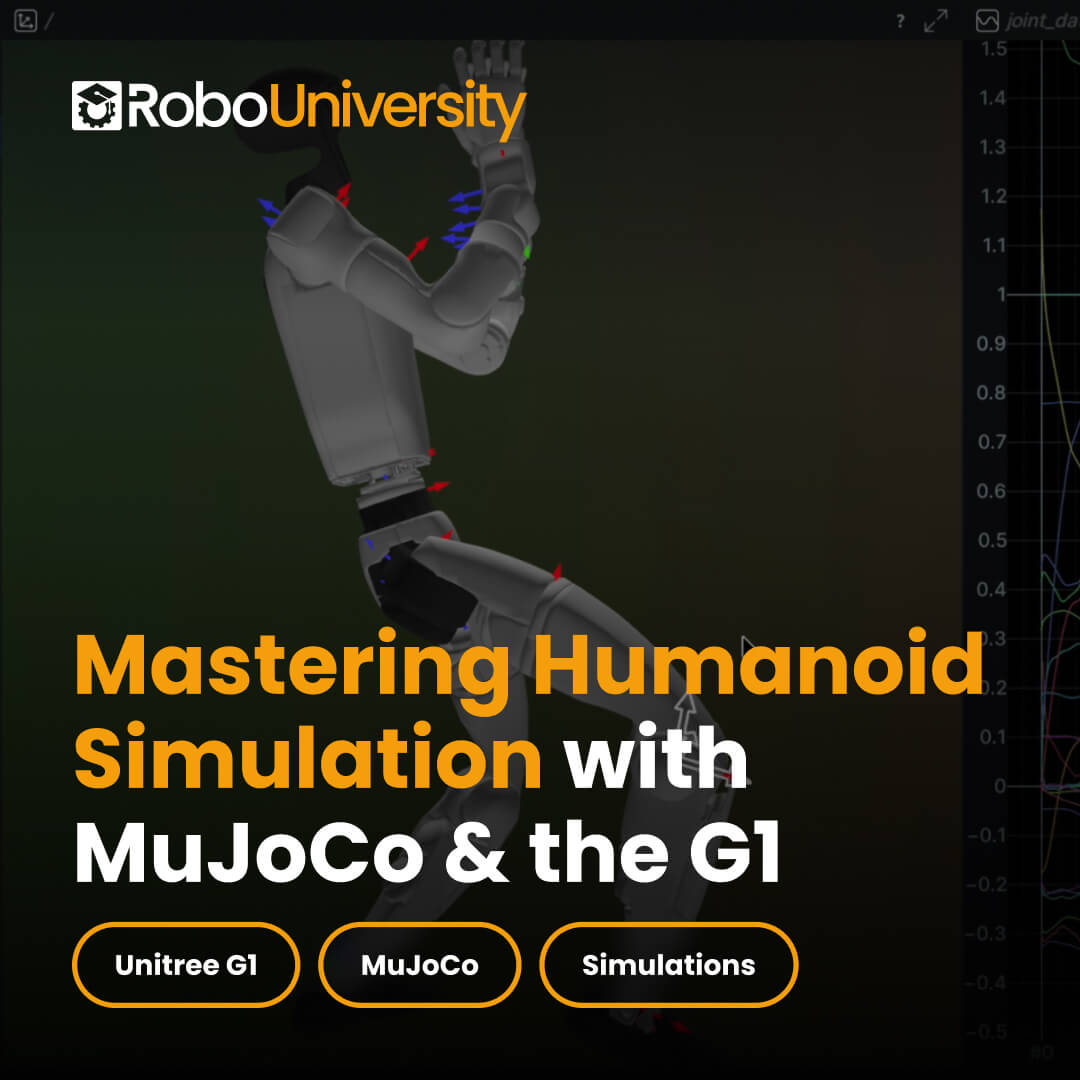
Mastering Humanoid Simulation with MuJoCo & the G1

Make It a Bundle
All-Access + Unitree G1 EDU
The robot every lesson runs on, on one invoice. Your choice of model, U1 to U8.
How It Works
- 1Get All-Access, or send us a purchase request.
- 2Receive your login by email.
- 3Start any RoboUniversity course: video lessons, structured learning and practice code.

Buying for a class or team? All-Access covers your whole organization.
How access works
After checkout we email your RoboUniversity login. Lessons, videos and sample code live in the online classroom, and you can return any time from Class Login.
Class and team access
Buying for a class, lab or team? All-Access is an enterprise-wide license that covers everyone.Speak to an expert.
Course at a Glance
Robot
Video lessons
Time to complete
Level
Prerequisites
Of completion
Course Syllabus
Module 1 · Getting Started10 lessons · 22 min
- 1.1 Install MuJoCo software and verify setup1:16
- 1.2 Learn MuJoCo’s interface - start, pause, reset, and analyze runtime stats1:56
- 1.3 Mujoco Unitree G1 Joint Angles1:56
- 1.4 Getting Started with LocoMuJoCo3:08
- 1.5 Downloading Motion Data and Testing1:53
- 1.6 Visualizing Dance Movement Data in RerunFree preview2:06
- 1.7 Visualizing Fighting and sports Movements in Rerun.io2:43
- 1.8 Visualizing Sports movements in Rerun2:31
- 1.9 Visualizing Jump Movements in Rerun2:42
- 2.0 Sim to Real Kinematic Motion Transfer- Fight DataFree preview2:44
What you'll learn
- MuJoCo installation & humanoid setup
- Simulation controls & interface navigation
- Solver tuning for stable humanoid motion
- Environmental & contact physics configuration
- Loading and replaying Unitree G1 datasets
- Human motion transfer concepts (LAFAN1)
- Interactive G1 control & debugging
- 3D motion visualization with Rerun

Whats Included?
Step-by-step lessons
Structured lessons that walk you through programming and development concepts clearly and progressively.
Video instruction
Guided video walkthroughs and demonstrations that show real workflows and examples in action.
Sample code
Hands-on code examples you can use, modify, and build on to start working immediately.
Community support
Access to a growing network of learners and professionals working with Unitree robotics.
What you’ll learn
You’ll learn everything from installing MuJoCo to replaying and visualizing G1 motion.
MuJoCo installation, humanoid setup and interface navigation.
Solver tuning, environmental and contact physics.
Load and replay G1 datasets, with LAFAN1 motion transfer concepts.
Interactive G1 control, debugging and 3D visualization in Rerun.
Tools you’ll use
More courses
Explore Every RoboUniversity Course
Buy courses one at a time, or get every course with All-Access.
 Free preview
Power on, connect, update and safely operate the Unitree G1 humanoid. A quick-start course with 6 short video lessons, from first setup to safe packing.
 Beginner
 6 lessons
 ~7 min
 Beginner
 6 lessons
 ~7 min

Generate, guide and export Unitree G1 humanoid motion data with Kimodo: text-prompted motion, keyframes, constraints and CSV export. Beginner friendly.
- Beginner
- 12 lessons
- 12+ hours
 Free preview
Install ROS 2, build Python and C++ packages, integrate the Unitree G1 SDK with a ROS-to-SDK bridge, then run the same control workflow safely in MuJoCo.
 Intermediate
- 21 lessons
- ~2–4 hours
 Intermediate

Build a real-time WebRTC command pipeline for Unitree Go2 and G1 with z4rtc: LAN connection, locomotion and gestures, video and audio streaming, LiDAR.
- Intermediate
- 12 lessons
- 18 min of video
 Free preview
Install DimOS on the Unitree G1 and build autonomy: navigation engine, perception, AI agents, mapping, autonomous navigation and custom agent skills.
- Intermediate
- 15 lessons
- 12+ hours
 Free preview
Build and deploy Vision-Language-Action systems on the Unitree G1: visual navigation, dexterous manipulation and world modeling with UniFoLM and GR00T.
 Advanced
- 9 lessons
- ~3–6 hours
 Advanced

Take the Unitree G1 from keyboard locomotion to autonomous manipulation with NVIDIA GEAR-SONIC and GR00T N1.6: teleop, data, fine-tuning and deployment.
- Advanced
- 8 lessons
- ~8–12 hours
 Free preview
Build, train and deploy locomotion policies with NVIDIA Isaac Sim, Isaac Lab and RSL-RL, then transfer them to a real robot. An end-to-end Sim2Real course.
- Advanced
- 7 lessons
- ~3 hours
 Free preview
Teach the Unitree G1 humanoid to move from human video: build motion datasets, train control policies and deploy them on a real G1 with HDMI.
- Advanced
- 6 lessons
- ~4–5 hours
 Free preview
Go from a fresh RoboJuDo install to real-hardware deployment on the Unitree G1 (29-DOF): architecture, policies, pipelines and safe simulation practice.
- Advanced
- 10 lessons
- 8–10 hours

Collect demonstrations, clean LeRobot datasets, fine-tune an Isaac-GR00T N1.7 VLA policy and deploy it on the Unitree G1 with PolicyServer.
- Advanced
- 8 lessons
- 5–8 days
Trusted by Top Universities and Schools
We’re partnering with the best to train the brightest minds in the future of robotics.


Frequently Asked Questions
How Does Access Work After I Buy?
Courses are delivered through RoboUniversity’s online classroom. After checkout we email your login, and you can return any time from Class Login.
Is This Course Included in All-Access?
Yes. All-Access includes every RoboUniversity course, including this one, plus future releases for 1 year at no extra cost.
What Hardware and Software Do I Need?
You would typically need a Unitree G1 and a computer. Some courses specifically require a Linux operating system, Python, and potentially software like Isaac Sim or the Unitree Explore app.
Does All-Access Cover a Whole Class or Team?
Yes. All-Access is an enterprise-wide license, so it covers every seat in your organization. Speak to an expert and we’ll set it up.
Do Courses Include Access to Simulations, and What Are the Requirements?
Access to simulations is provided, but you would need to have the corresponding Unitree hardware to utilize them effectively.
Why RoboUniversity?

01
JUMP IN FASTER
Step-by-step lessons remove the steep learning curve of robotics, allowing students to start building quickly without educators creating curriculum from scratch.

02
BUILT BY PRACTITIONERS
Courses are created by professionals actively working with Unitree robotics, grounded in real-world applications rather than generic theory.

03
BUILT FOR UNITREE HARDWARE
Lessons are designed specifically for the Unitree G1 humanoid, so what you learn directly applies to the hardware you are using.
Get in touch
Prefer to talk?
Book a Discovery Call
Tell us about your team and robots, and we’ll put the robot and the curriculum on one quote.